Robotics
Arduino
Embedded Systems
Load Analysis
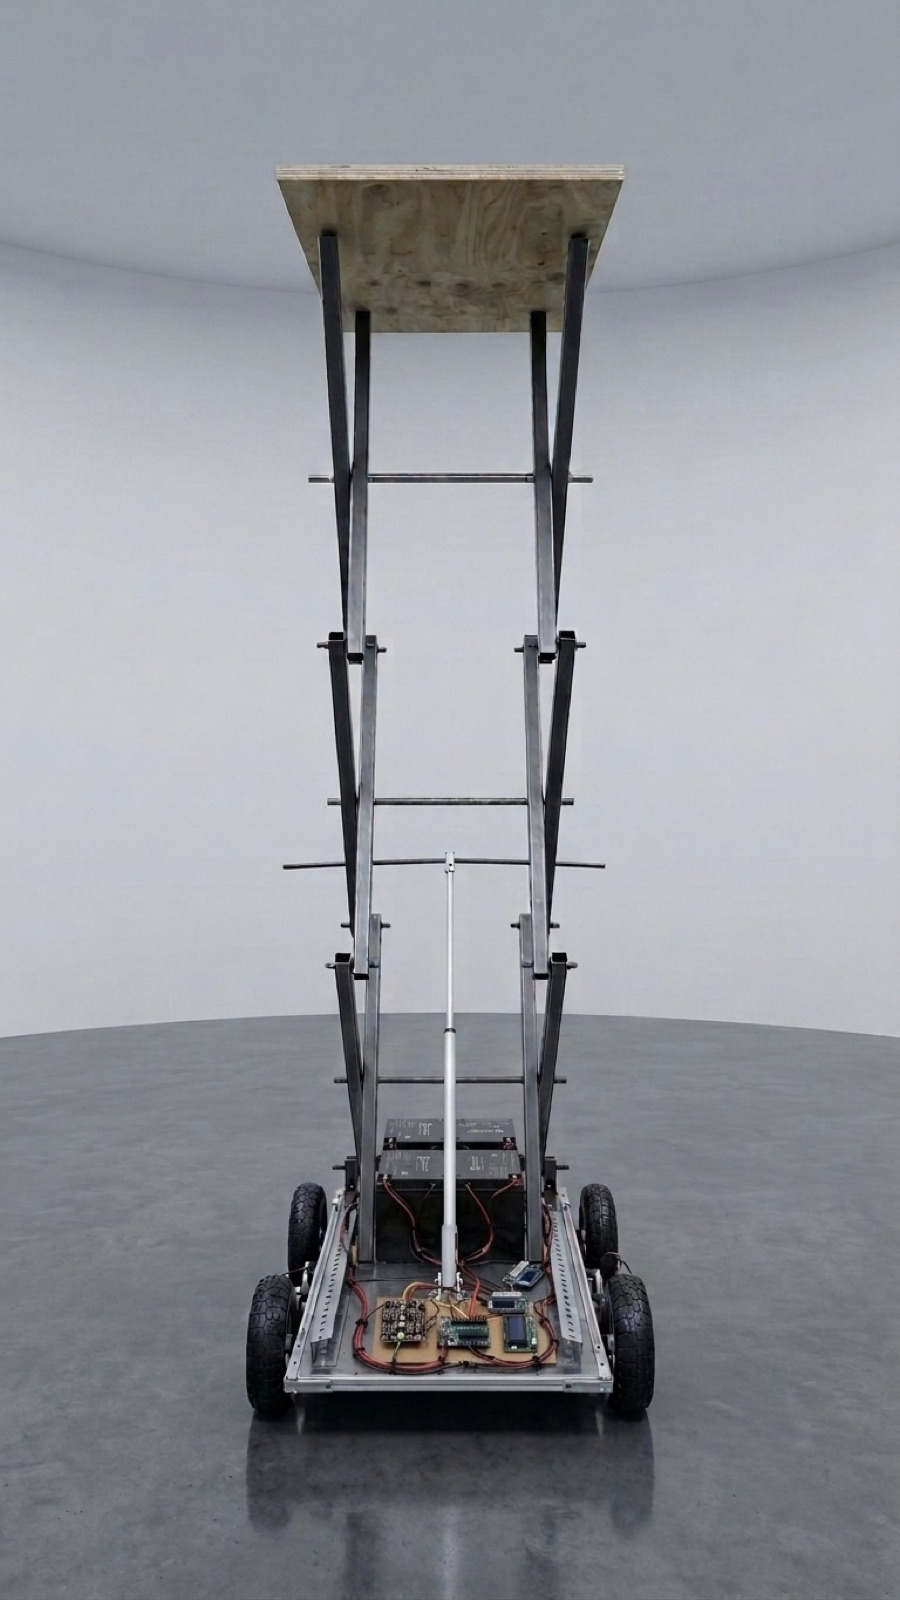
X-FLEX Compact Scissor Lift
Senior Capstone project, 6-member team. Original concept used tank tracks, a hydraulic pump, and a PLC controller; reworked each as the design matured. Worked on embedded control with the team: programmed an Arduino Mega 2560 to parse FlySky RC receiver input and output PWM to Cytron MDD10A motor drivers for chain-and-sprocket differential drive. Lift motion comes from a single 24V linear actuator in place of the original hydraulic pump, with deadman and limit switches wired for fail-safe shutdown. Built to move loads through standard indoor doorways and elevators where full-size scissor lifts can't fit.
Result: Lifted 200 lb to 8 ft, held a 180 lb person jumping on the base plate with no damage, and cleared standard interior doorways and elevators at 34 in wide. Presented at Wentworth's Senior Capstone Showcase.
View Details →